Deep learning for self-tuning of control systems
In brief
Using deep learning to tune a control system's settings automatically instead of by hand.
Abstract
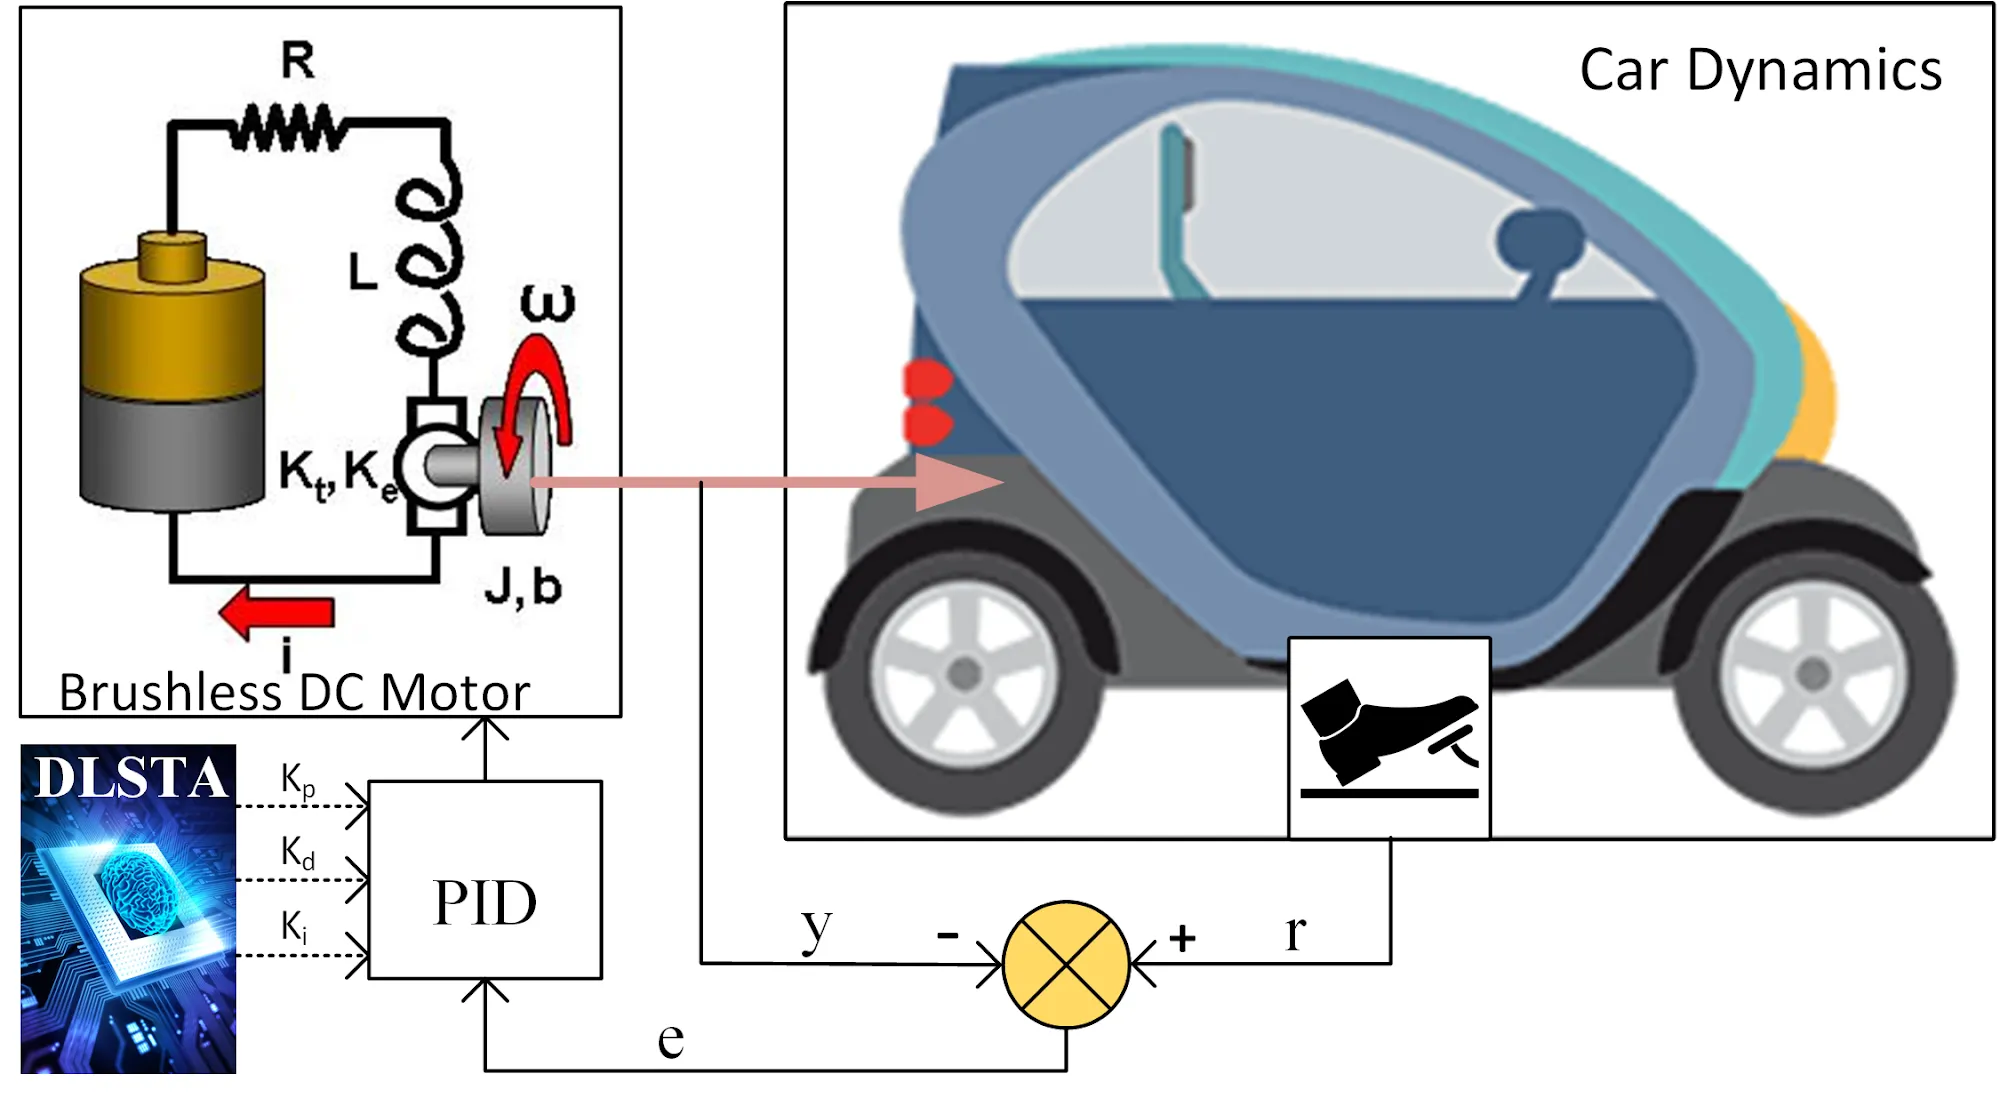
This paper proposes an innovative two-dimensional multi-layered deep neural network (DNN) to achieve adaptive, physics-informed, model-free and data-based control of stochastic, sensitive and highly nonlinear systems. The algorithm design exploits the DNN features of adaptive learning, inference of latent variables and time-series prediction to update the controller parameters on-the-run in real-time while compensating for the loop delays at the same time in addition to the system processing time. The proposed deep learning based self-tuning algorithm (DLSTA) is generic and can be used for online self-tuning of controller parameters in general. For the purpose of this paper, it is applied on the speed control of the brushless DC (BLDC) motor in an electric vehicle (EV) using PID controller on the front-end. The simulation results demonstrate the superiority of the proposed scheme over other conventional tuning methods.
Talk
Watch the conference presentation on YouTube. Conference presentation of the paper that received the Best Paper Award at ICETCI 2021.
Cite this paper
@inproceedings{farooq2021deep,
  title   = {Deep learning for self-tuning of control systems},
  author  = {Farooq, Junaid and Bazaz, Mohammad Abid},
  booktitle = {ICETCI 2021, IEEE},
  year    = {2021},
  pages   = {6--11},
  doi     = {10.1109/ICETCI51973.2021.9574048},
}
Topic: Scientific machine learning